Rachel Hoffman-Bice, PhD
Mechanical Design · Robotics and Controls · Medical Devices · Warehouse and Factory Automation
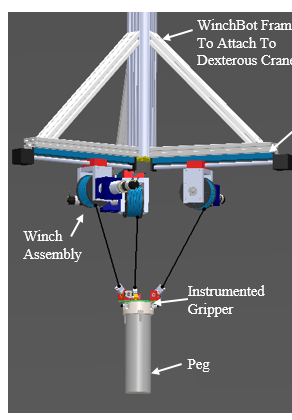
I grew up in a small town just outside Pensacola, Florida, earned my B.S. in Mechanical Engineering from the University of Florida in 2015, and went on to MIT for a Master’s (2017) and PhD in Mechanical Engineering in the d’Arbeloff Laboratory (2021) with a focus on Robotics and Machine Design. My graduate research focused largely on topics relating to warehouse and factory automation. For my Master’s degree, I designed and modeled an alternative object retrieval system to let e-commerce companies put fulfillment centers in dense urban areas. My PhD research focused on the design of a custom robotic gantry crane and the precision insertion of extremely heavy cable-suspended pegs, a challenging problem due to the unidirectional stiffness of cables.
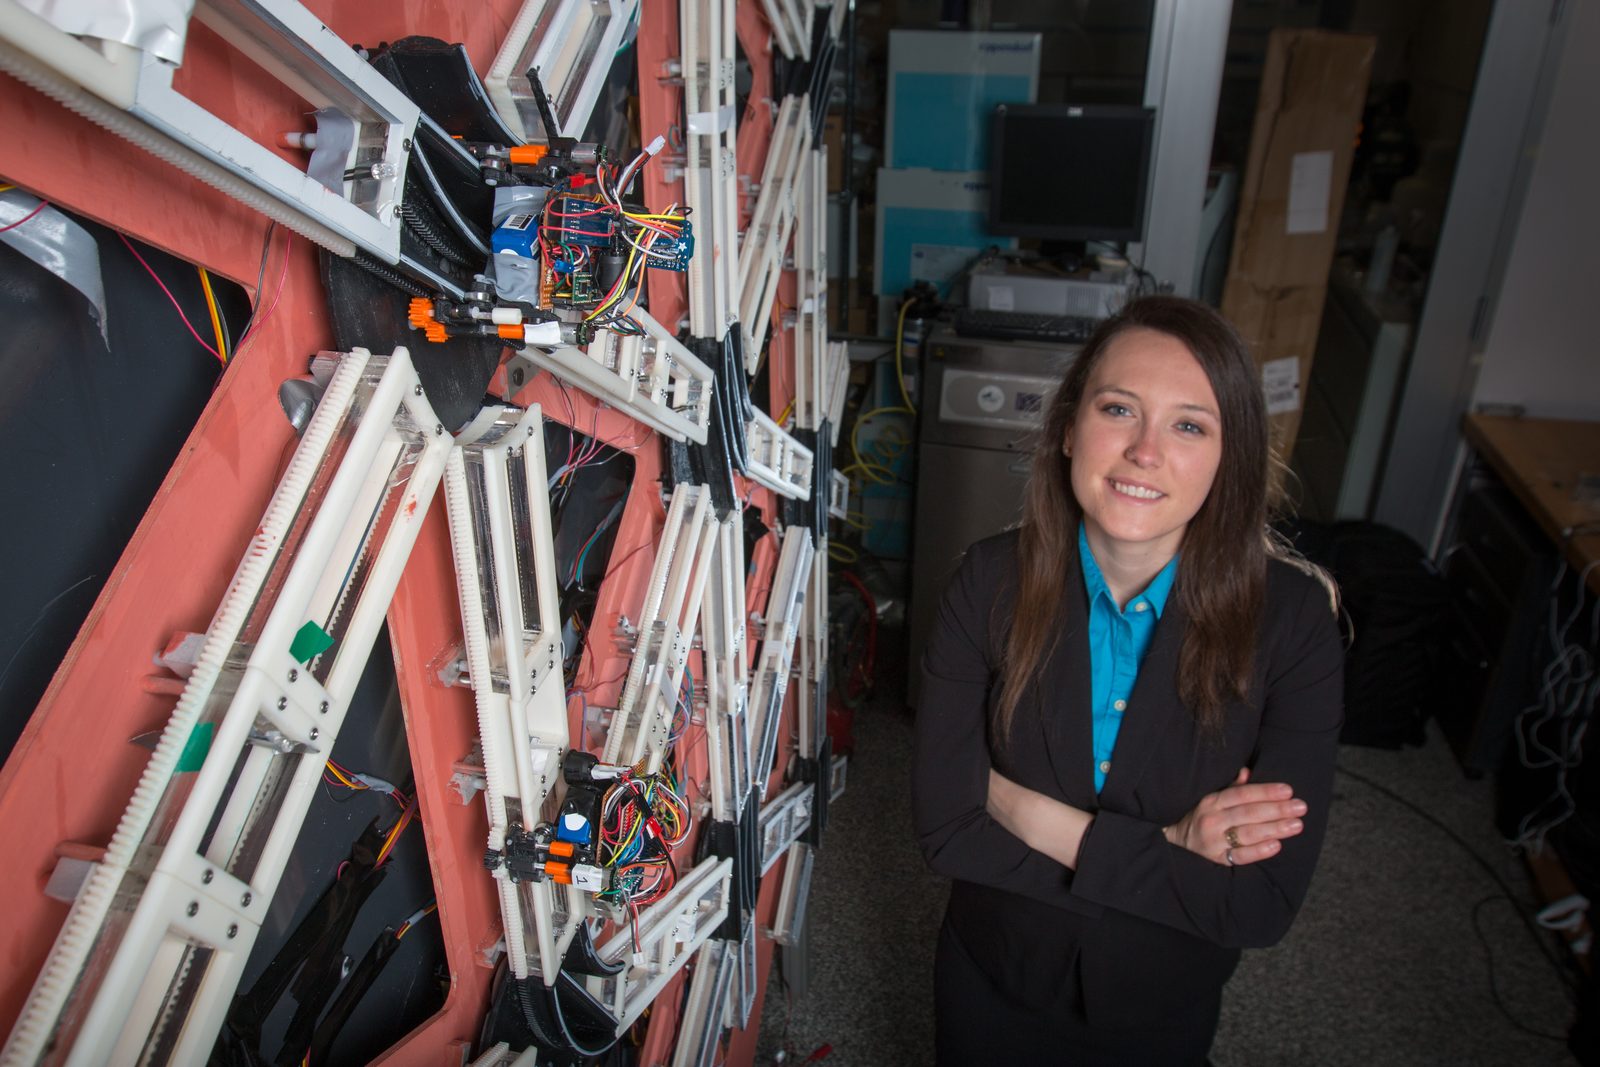
I have a passion for challenging problems that can be solved through a combination of clever mechanical design and innovative control theory. My primary topics of interest are technology related to women’s health, surgical robotics and warehouse and factory automation.
Education [3]
-
PhD
Mechanical Engineering
Specialization in Robotics and Machine Design
Dissertation: Precision Assembly of Underconstrained Heavy Shafts Suspended By Multiple Cables From A Robotic Crane. Minor in Leadership and Management. GPA 4.9/5.0.
-
SM
Mechanical Engineering
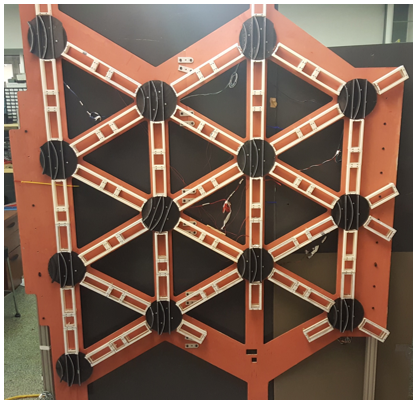
Thesis: A Multi-Track Elevator System for E-Commerce Fulfillment Centers, which won the Best Application Paper Award at IROS 2017. GPA 4.9/5.0.
-
BSME
Mechanical Engineering
Summa cum laude with a minor in Electrical Engineering, GPA 3.97/4.0. Outstanding Four-Year Scholar Commencement Award, one of three across the College of Engineering.
Experience [6]
Projects [14]
-
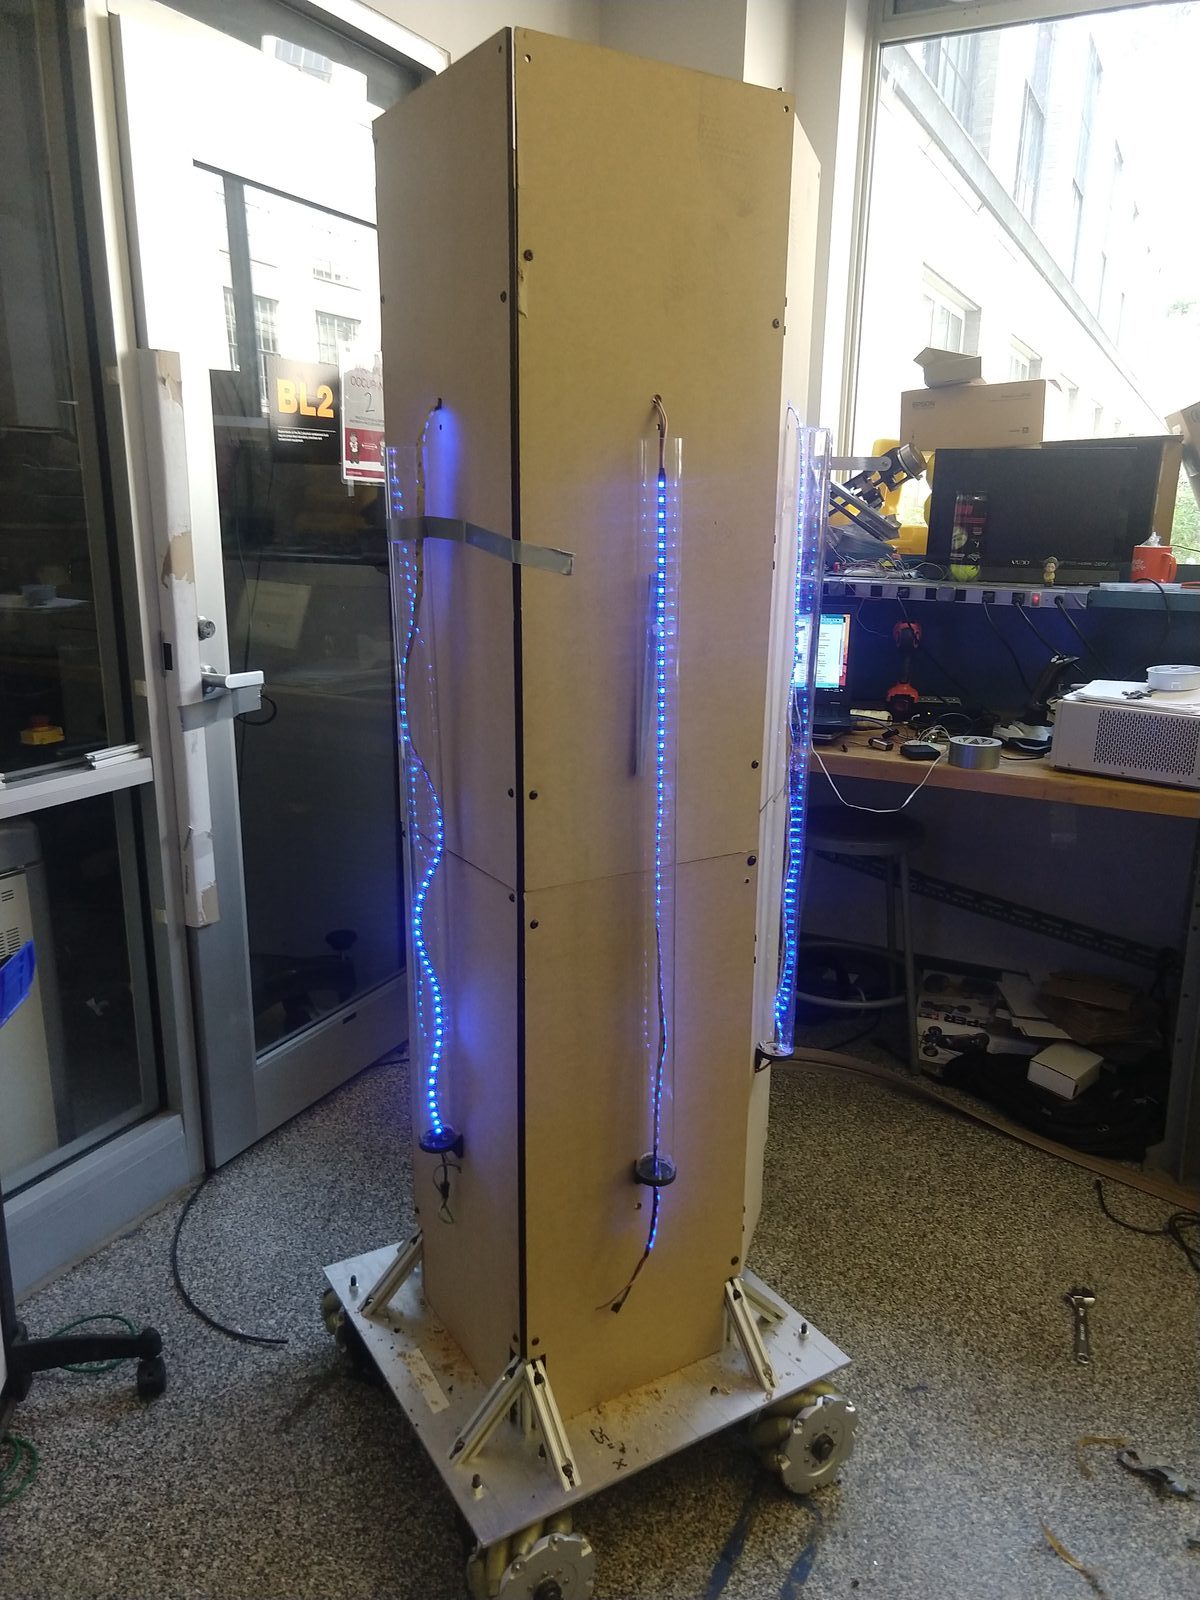 UV Disinfection Robot
2020
-
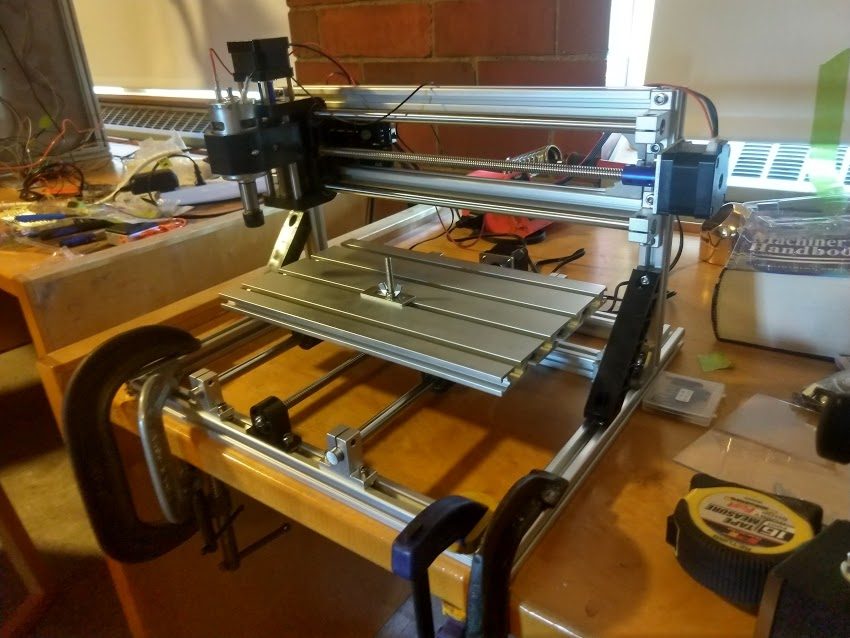 Desktop CNC Router Assessment
2020
-
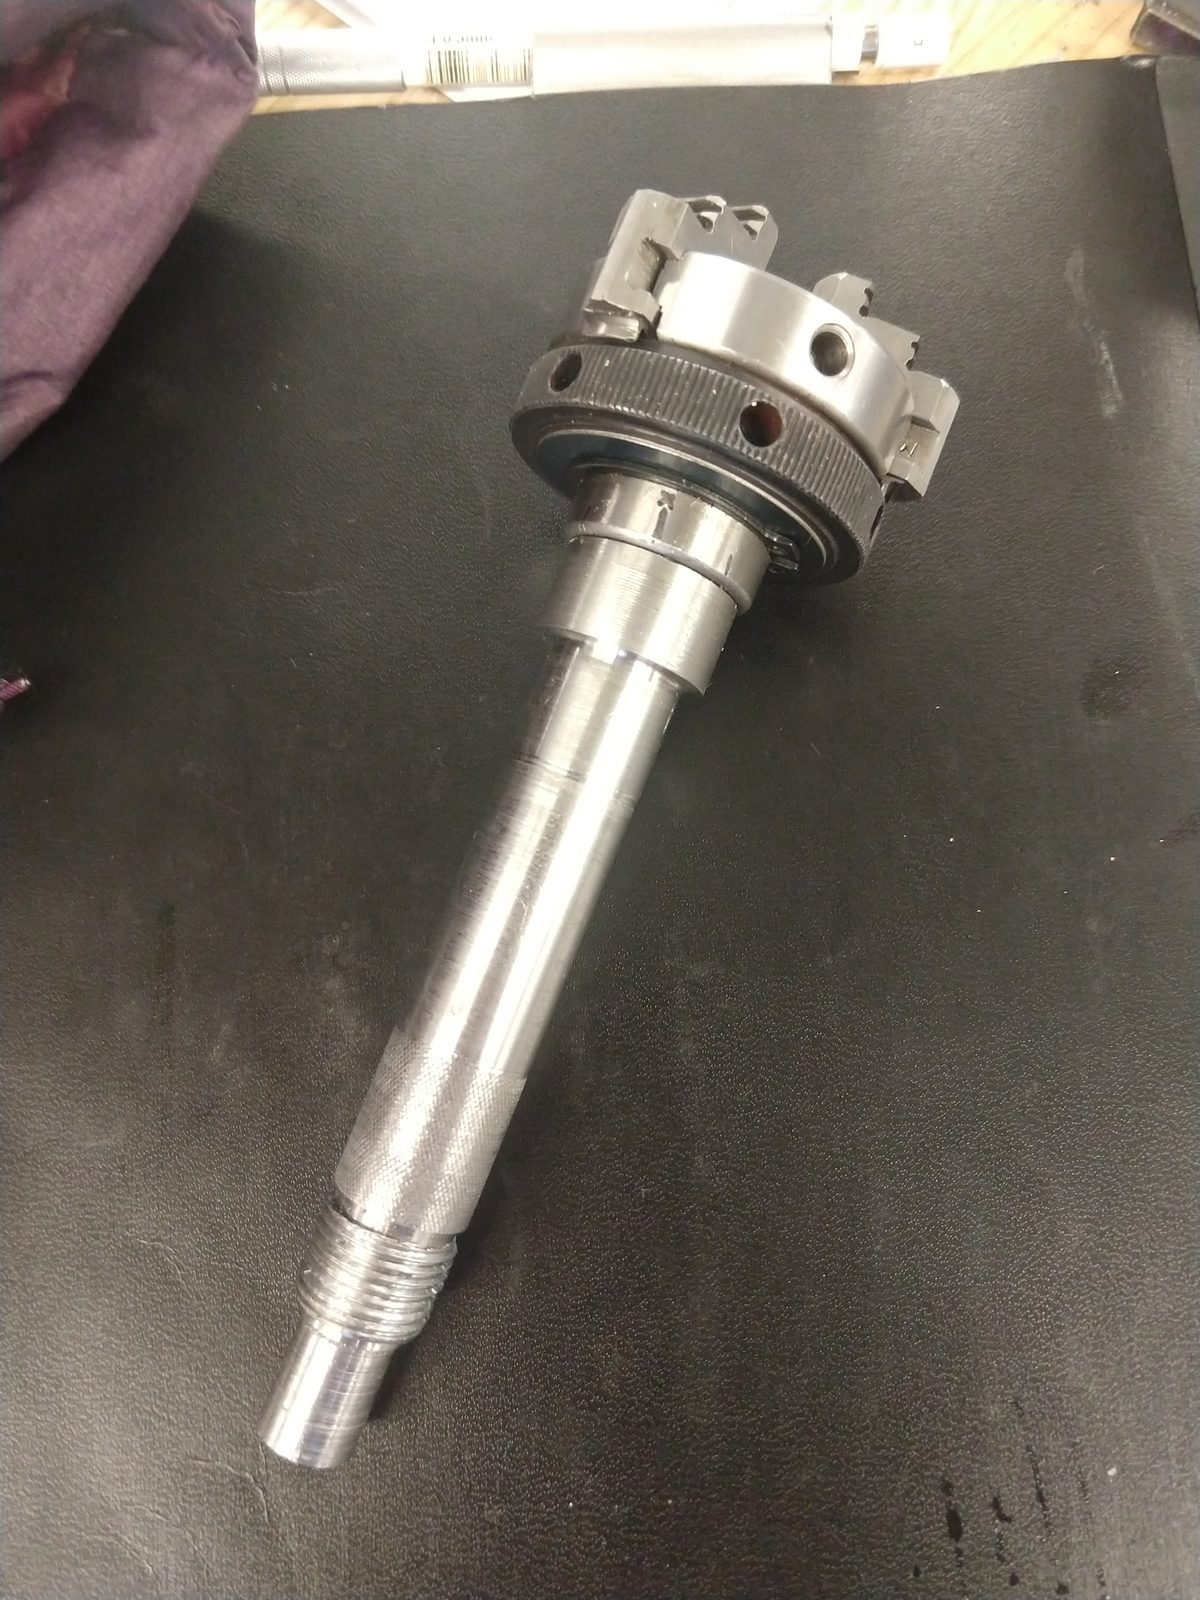 Lathe Spindle
2020
-
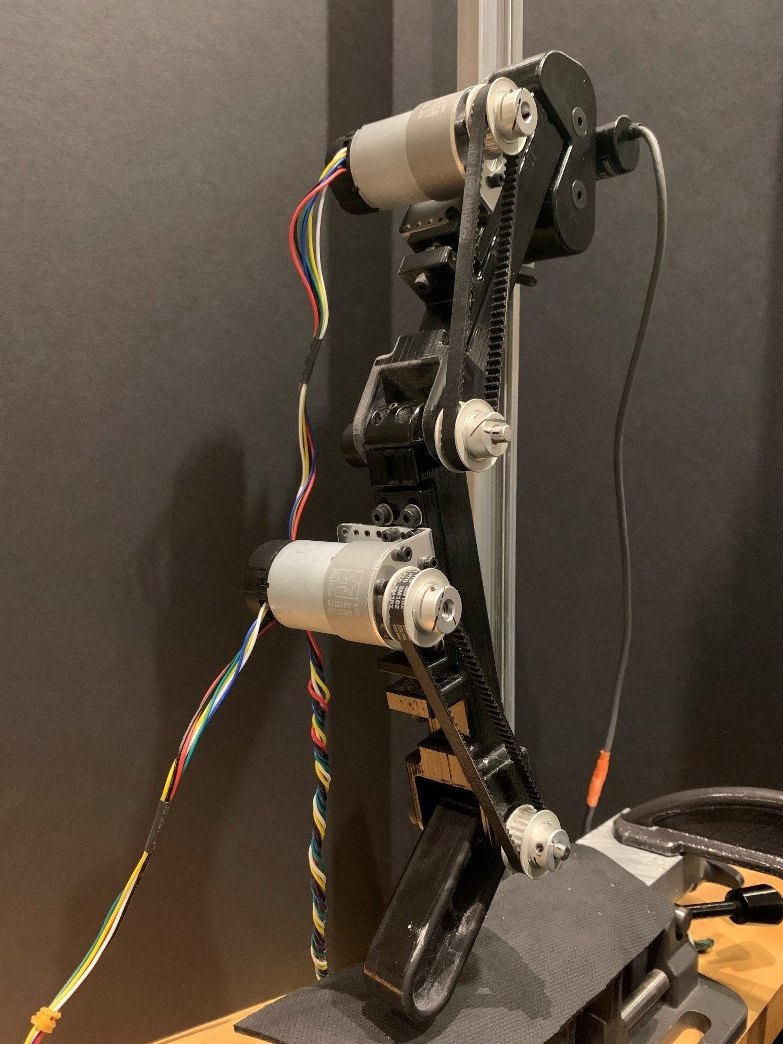 GRAC — Compliant Robotic Leg
2019
-
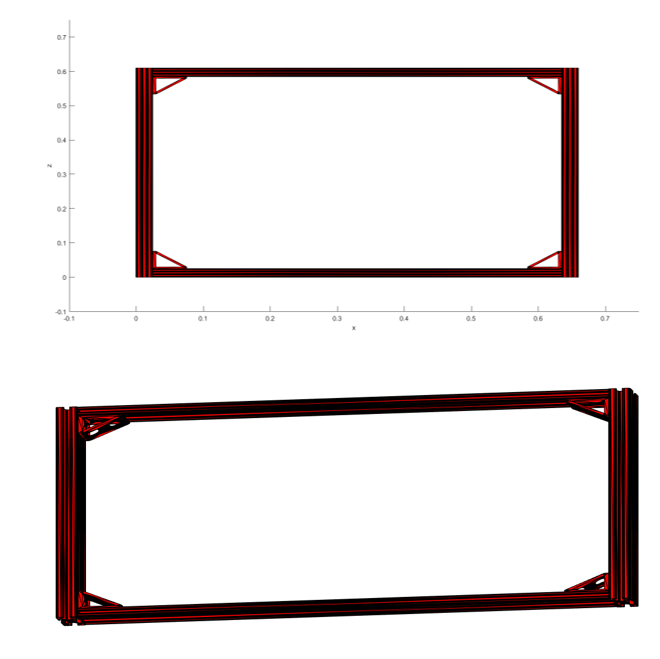 Disassembly Matrices from CAD Meshes
2019
-
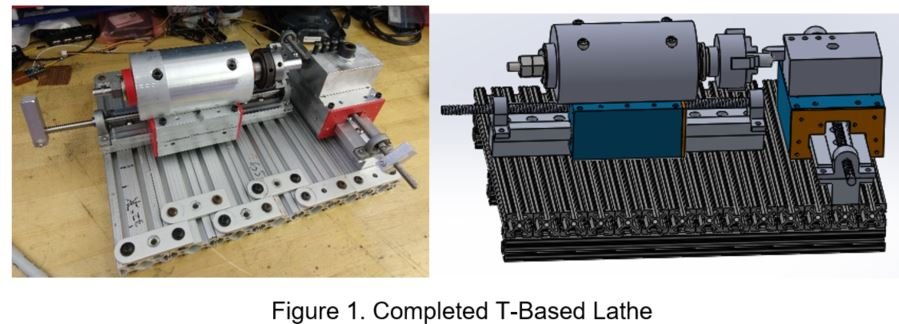 T-Based Precision Lathe
2018
-
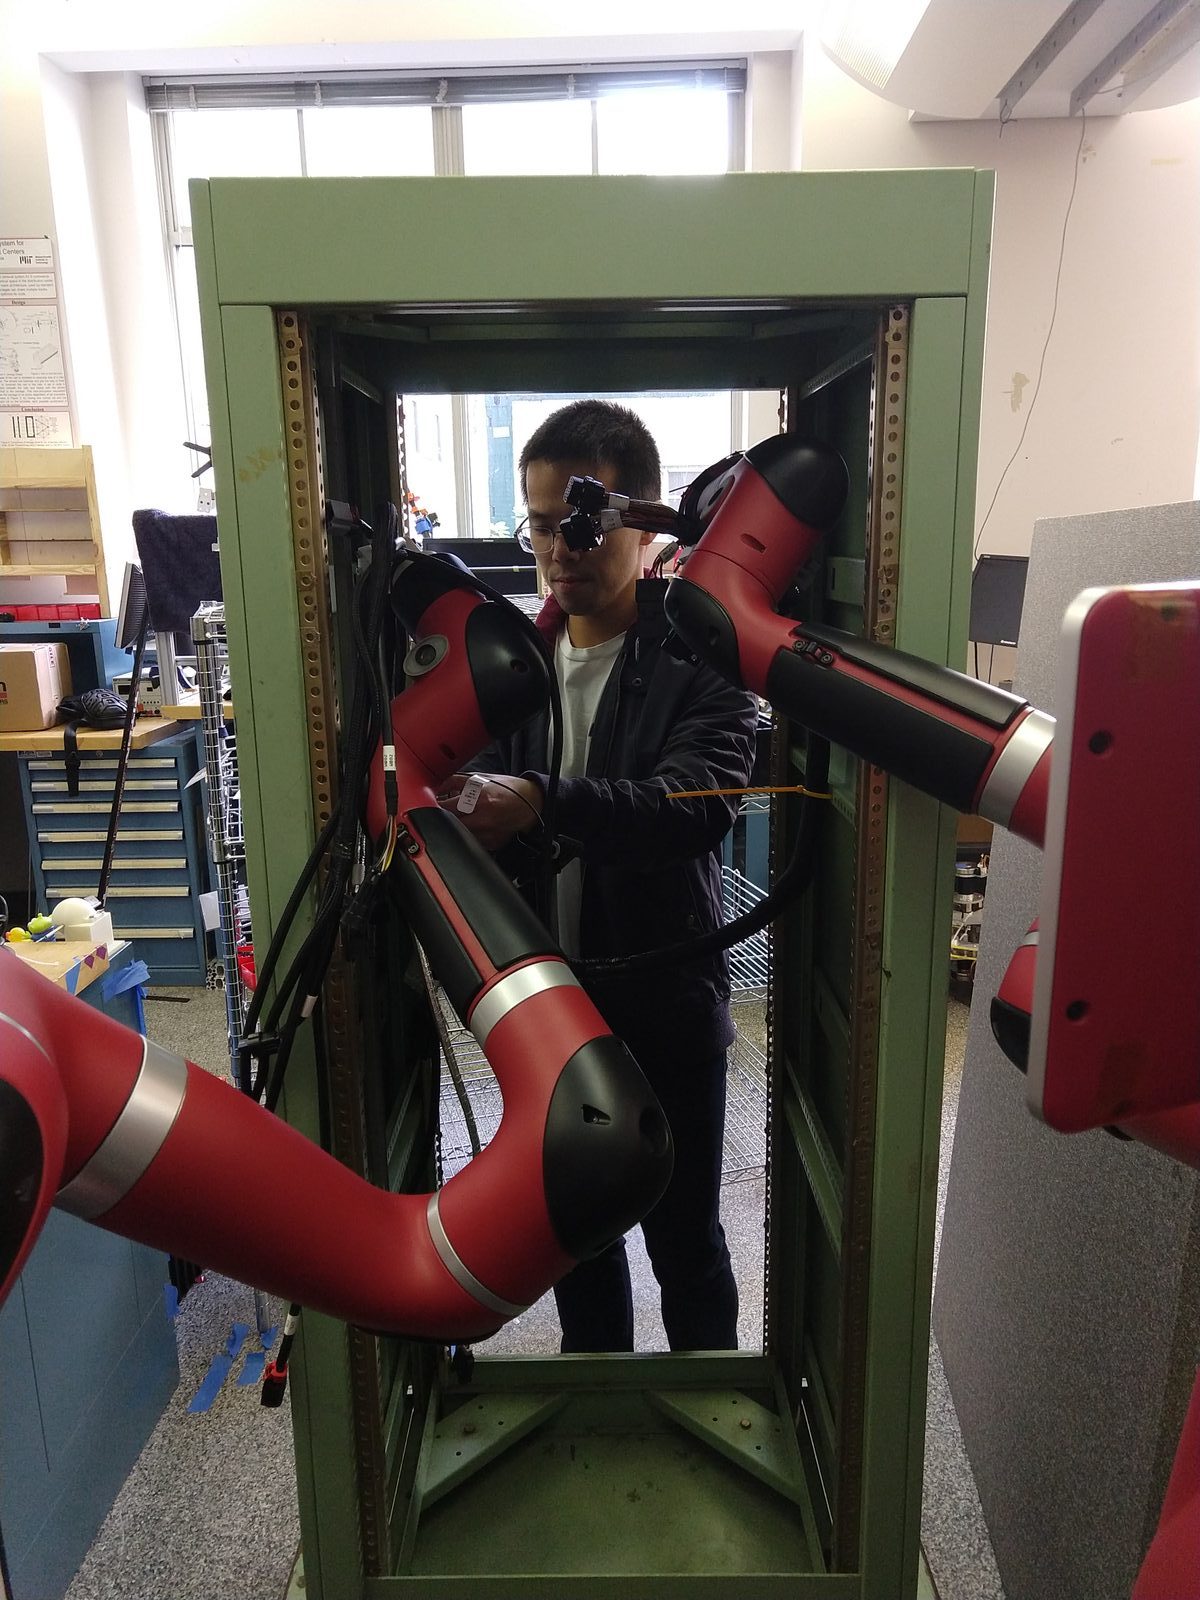 RAWHIDE — Robotic Assisted Wire Harness Installation
2018–2019
-
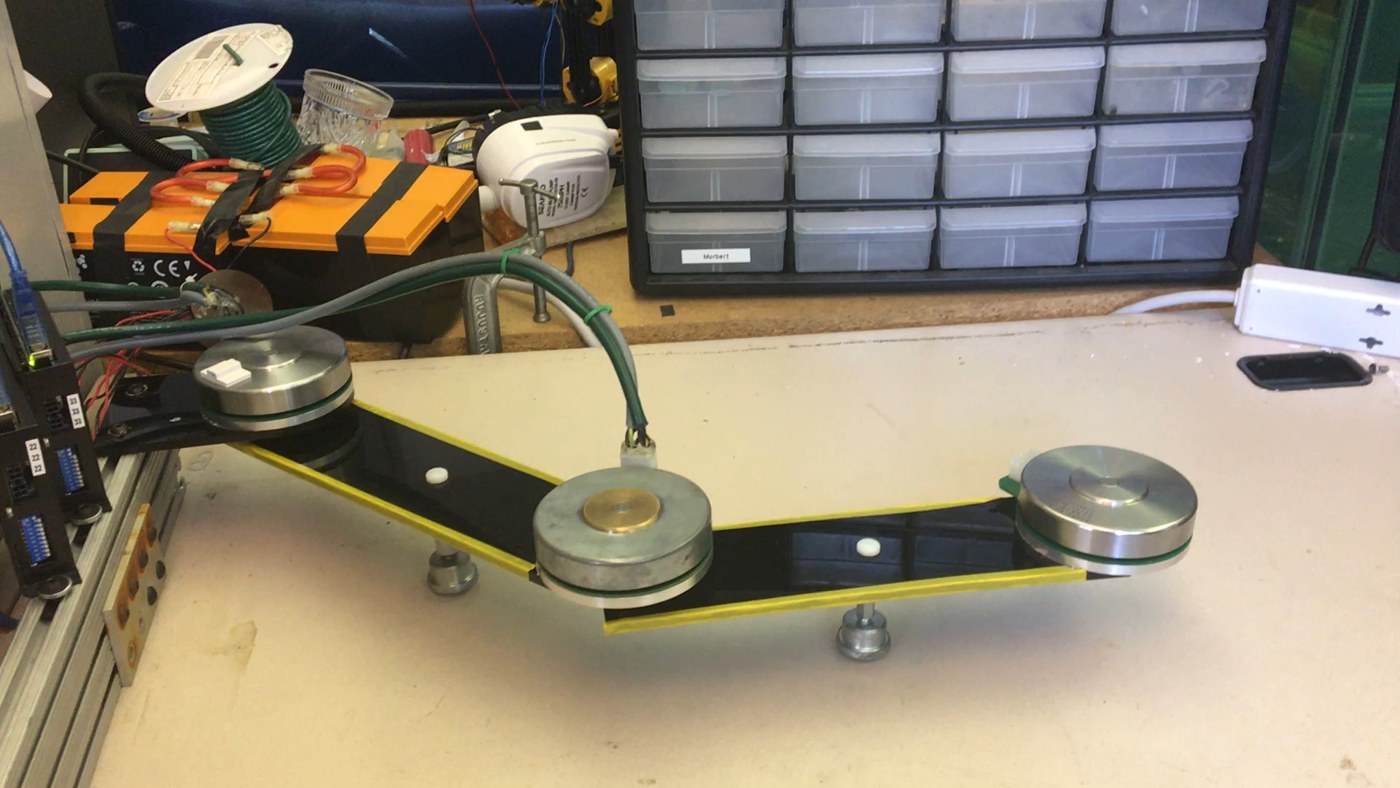 Equilibrium-Point Robot Arm
2017
-
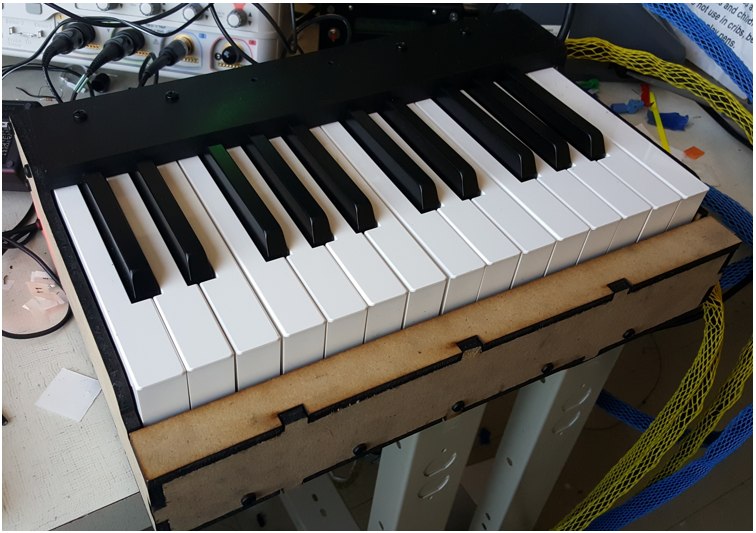 MEG-Compatible Keyboard
2016
-
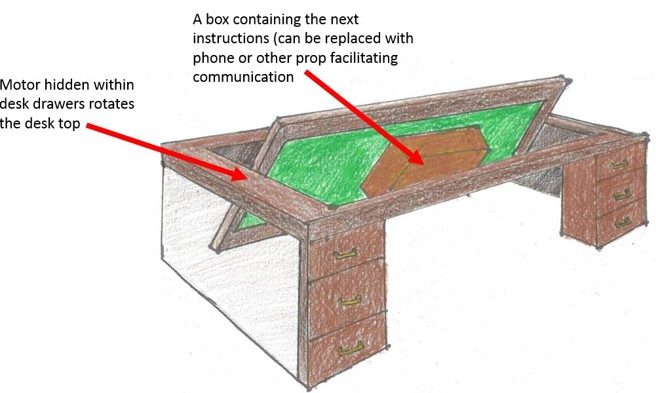 Mystery Manor Reveal Effect
2016
-
 Blizzard Rescue
2015
-
 DrumBot
2015
-
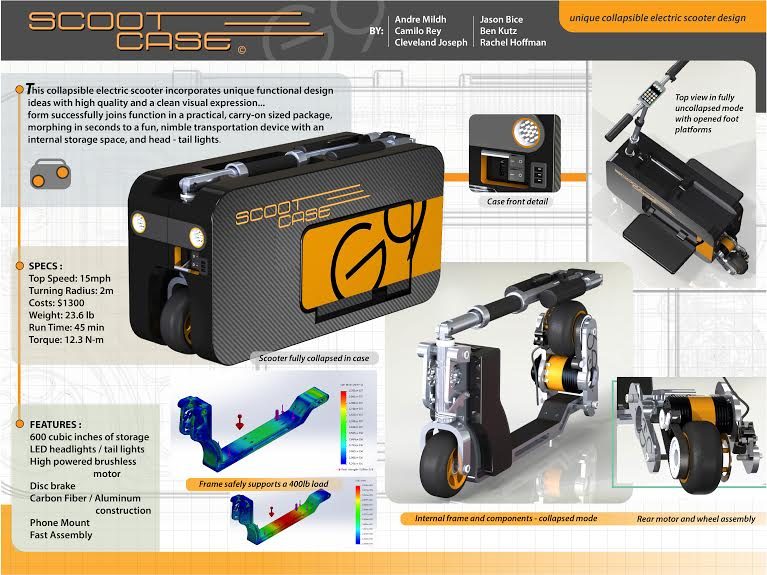 Scoot Case
2014–2015
-
 Slalom Course Robot
2012
Publications [9]
- 2021 Precision Assembly of Underconstrained Heavy Shafts Suspended By Multiple Cables From A Robotic Crane
- 2021 Control Strategy for Jam and Wedge-Free 3D Precision Insertion of Heavy Objects Suspended with a Multi-Cable Crane
- 2020 Leveraging the Human Operator in the Design and Control of Supernumerary Robotic Limbs
- 2020 Precision Assembly of Heavy Objects Suspended with Multiple Cables From a Crane
- 2020 Device Prototype for Vaginal Delivery of Extremely Preterm Fetuses in The Breech Presentation
- 2017 A Multi-Track Elevator System for E-Commerce Fulfillment Centers
- 2017 Music and the Brain – Design of an MEG Compatible Piano
- 2017 A Multi-Track Elevator System for E-Commerce Fulfillment Centers Winner, Best Application Paper Award
- 2015 A Method for Obtaining Formula One Race Track Curvature for Use in Solving Minimum Lap Time Optimal Control Problems